
NAME
r.dem.bias - Remove terrain-correlated systematic bias from a DoDKEYWORDS
raster, DEM, bias, change detection, regressionSYNOPSIS
Flags:
- --overwrite
- Allow output files to overwrite existing files
- --help
- Print usage summary
- --verbose
- Verbose module output
- --quiet
- Quiet module output
- --ui
- Force launching GUI dialog
Parameters:
- dod=name [required]
- Input DEM of Difference raster to correct
- output=name [required]
- Output bias-corrected DoD raster
- method=string [required]
- Bias-correction method
- Options: regression, forest, spline
- predictors=name[,name,...]
- Terrain predictor rasters (method=regression)
- stable_mask=name
- Stable-terrain mask defining the regression fit region (method=regression)
- mask=name
- Mask of cells used for the local bias field, e.g. forest (method=forest)
- bias_field=name
- Optional output of the estimated bias field that was subtracted
- output_se=name
- Output coefficient-uncertainty SE raster of the bias model, sqrt(x' Cov x) (method=regression, 1 sigma, excludes residual variance)
- output_leverage=name
- Output extrapolation-distance raster d = sqrt(n*h - 1) in fit-sd units (method=regression)
- fit_json=name
- JSON file persisting the fit (n, s2, coefficients, covariance, transforms; method=regression)
- spline_tension=float
- v.surf.rst tension for the spline bias field (method=spline)
- Default: 40.0
- spline_smooth=float
- v.surf.rst smoothing for the spline bias field (method=spline; oversmoothing is the safe direction for a long-wavelength field)
- Default: 5.0
- spline_npoints=integer
- Stable cells sampled as spline fit points (method=spline; deterministic seed)
- Default: 50000
- spline_res=float
- Interpolation resolution (m) for the spline bias field, resampled bilinearly to the analysis grid (method=spline)
- Default: 10.0
- log_predictors=string[,string,...]
- Predictors to log-transform before z-scoring (must be listed in predictors; explicit, never data-triggered)
- window=integer
- Window size in cells for the local bias field (method=forest)
- Default: 21
- trim_low=float
- Lower trimming percentile for the local bias core (method=forest)
- Default: 2.5
- trim_high=float
- Upper trimming percentile for the local bias core (method=forest)
- Default: 97.5
Table of contents
DESCRIPTION
r.dem.bias removes terrain-correlated systematic bias that remains in a DEM of Difference (DoD) after rigid co-registration. Alignment tools such as r.dem.coregister, r.dem.nk, and r.dem.icp remove translation and rotation, but a residual elevation difference often still varies with terrain (for example a positive canopy bump in forest, or error that scales with slope, roughness, or point density). This tool models that residual and subtracts it.
Three methods are provided through the method option.
method=regression
Fits a multivariable linear model of the DoD on z-scored terrain predictors over stable terrain, then subtracts the fitted surface from the full DoD.
- The dependent variable is the DoD restricted to the stable_mask region.
- Each predictors raster is standardized to zero mean and unit variance, on a log scale for the predictors named in log_predictors (positive values only; a predictor carrying non-positive values falls back to the linear scale with a warning). Log transforms are explicit, never data-triggered.
- An ordinary-least-squares fit (numpy, on sampled stable cells; above 2
million cells a deterministic subsample is drawn) estimates the intercept,
per-predictor coefficients, and the coefficient covariance, and the fitted
bias field
b0 + sum(b_i * z_i)is subtracted from the DoD. - The optional output_se raster is the 1-sigma coefficient
uncertainty of the bias model,
sqrt(x' Cov x)on the transformed predictors. It deliberately excludes the residual variances2so downstream quadratures (r.dem.lod sigma_extra, r.dem.errprop sigma) do not double count. The covariance is iid OLS and understates coefficient uncertainty under spatially correlated residuals. - The optional output_leverage raster is the extrapolation distance
d = sqrt(n*h - 1)in fit-sd units, the distance-from-control map: coefficient uncertainty cannot express model-form error under extrapolation. - The optional fit_json file persists the whole fit (n, residual variance, intercept, coefficients, covariance matrix, applied transforms) so a reported correction can be reproduced without refitting.
Predictor rasters are typically produced by r.dem.stats (slope, roughness, landform diversity, local sigma) together with a reference-DEM uncertainty surface.
method=spline
Interpolates the stable-cell residuals into a smooth spatial bias field with v.surf.rst and subtracts it; no terrain predictors, no collinearity pathologies. The field is fit from spline_npoints randomly sampled stable cells (deterministic seed) at the coarse spline_res resolution with spline_tension and spline_smooth, then resampled bilinearly to the analysis grid. Most trustworthy near stable cells; validate with a holdout before trusting extrapolation.
method=forest
Estimates a local trimmed-median bias field over a masked subset of cells (classically a forest canopy bump) and subtracts it.
- Within the mask region the DoD is trimmed to its [trim_low, trim_high] percentile core to exclude outliers.
- A moving-window median of that core over a window-cell window gives the local bias field.
- Outside the mask the bias field is zero, so unmasked cells are unchanged.
However, a local trimmed median cannot separate a canopy bump from real elevation change, so any deposition or scour inside mask is removed along with the bias. Keep known and suspected change areas out of the mask, using the footprint from a coarse r.dem.screen pass where one is available.
NOTES
The optional bias_field output stores the estimated correction surface that was subtracted, which is useful for inspection and reporting.
For method=regression the corrected DoD is NULL wherever any
predictor is NULL (the fitted surface is undefined there); output_se
follows the same predictor-driven NULL pattern, and is defined even where the
input DoD is NULL.
The mask used by method=forest is applied through a temporary
mask context and is removed automatically; the user's existing mask and
computational region are left untouched. Intermediate rasters are removed on
exit.
EXAMPLES
The commands below use the example scene built in the r.dem toolset manual, which is derived from the North Carolina sample dataset. Build it there first.
The scene carries three bias components, and each method removes a different one. Chain them: no single method removes all three.
Start with the long-wavelength dome, fitted from the stable cells and interpolated across the map:
g.region raster=elev_lid792_1m

r.dem.bias dod=dod_raw output=dod_spline method=spline \
    stable_mask=stable_terrain bias_field=bias_spline
Then the canopy bump, estimated as a local trimmed median under the forest mask:
r.dem.bias dod=dod_spline output=dod_debiased method=forest \
    mask=forest window=21
The residual on stable terrain falls from 0.17 m to under 0.01 m, and the residual over forest falls from 1.68 m to under 0.01 m.
The regression path models the bias against terrain predictors instead, keeping the coefficient uncertainty for the uncertainty budget downstream:
r.dem.bias dod=dod_raw output=dod_regression method=regression \
    predictors=roughness stable_mask=stable_terrain \
    output_se=bias_se output_leverage=bias_leverage \
    fit_json=bias_fit.json
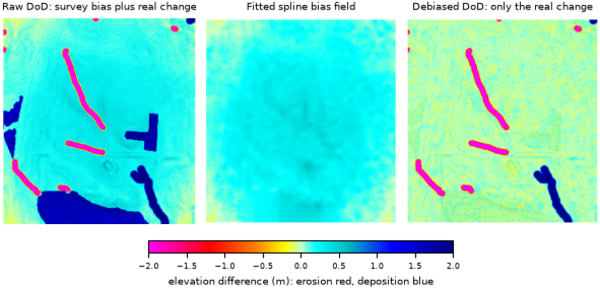
Figure: Raw DoD carrying the survey bias, the fitted spline bias field, and the difference after the spline and forest stages.
SEE ALSO
r.dem, r.dem.coregister, r.dem.errprop, r.dem.stats, r.neighbors, v.surf.rstAUTHORS
Corey T. White, Center for Geospatial Analytics, NC State University
SOURCE CODE
Available at: r.dem.bias source code (history)
Accessed: Sunday Sep 13 08:27:39 2026
Main index | Raster index | Topics index | Keywords index | Graphical index | Full index
© 2003-2026 GRASS Development Team, GRASS 8.5.1dev Reference Manual